Zelin Shen
Student at UMich Robotics | Agile Robot Control and Design Lab

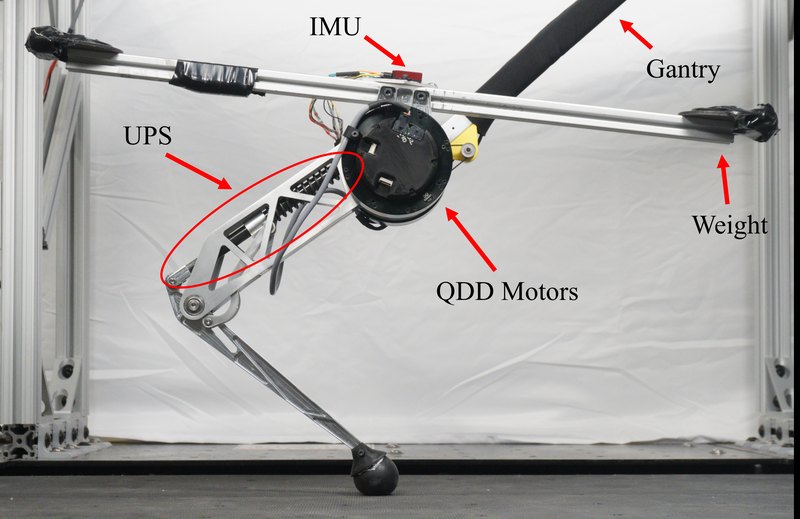
Hi, I’m Zelin 👋 I’m a master’s student in the Robotics Department at the University of Michigan, where I work on legged and humanoid robots as a research assistant in the Agile Robot Control and Design (ARCaD) Lab, advised by Prof. Yanran Ding.
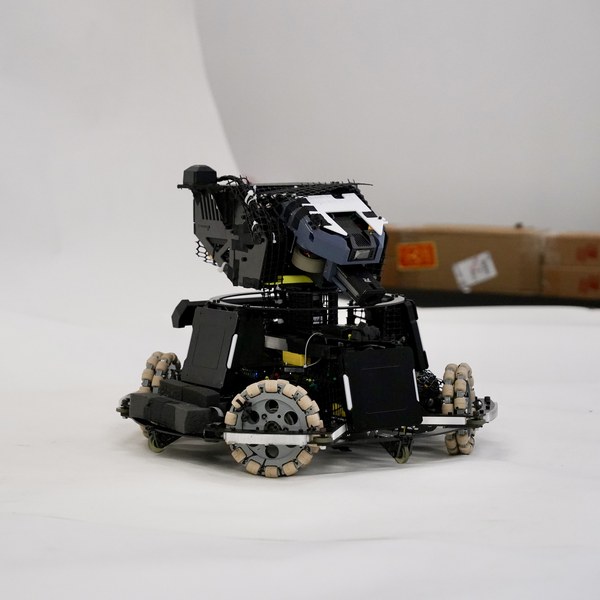
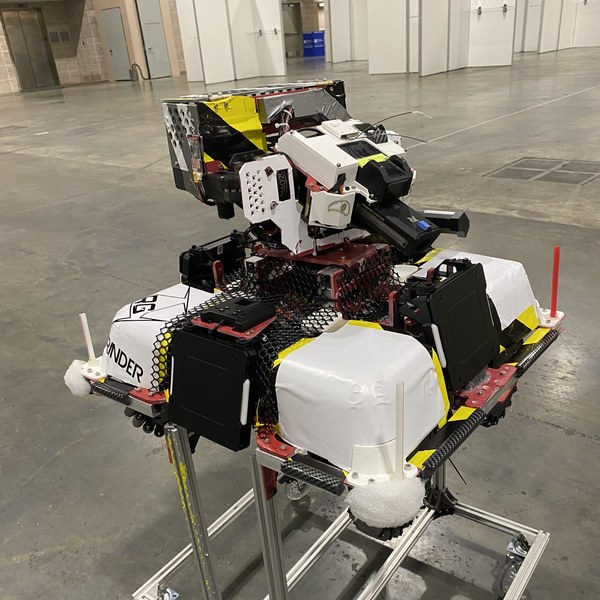
Before UMich, I was at Virginia Tech, where I earned my B.S. in Mathematics and B.S. in Computational Modeling & Data Analytics. During my undergraduate studies, I spent four years building competition robots with RoboGrinder, VT’s RoboMaster team, first as an embedded software developer and later as the lead of its ECE & embedded control branch. I like building robots end to end, from mechanical hardware and embedded firmware, through control, to higher-level applications.
News
| Aug 25, 2025 | Started my M.S. in Robotics at the University of Michigan. |
|---|
Publications
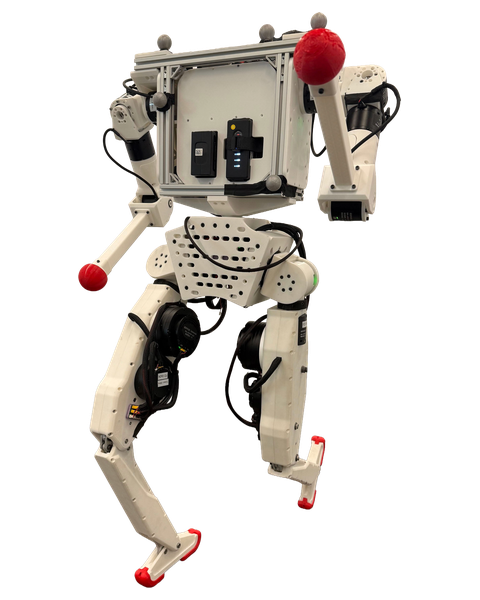
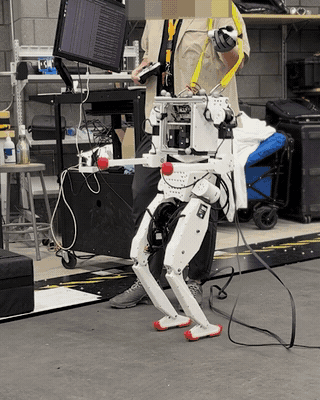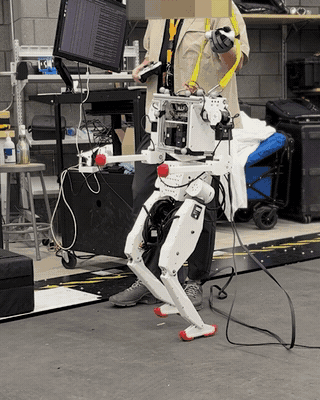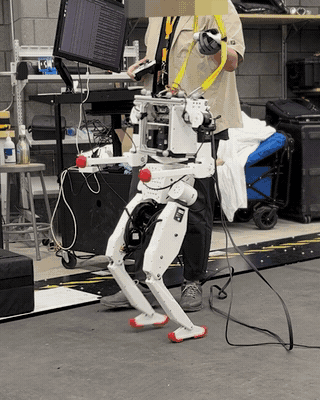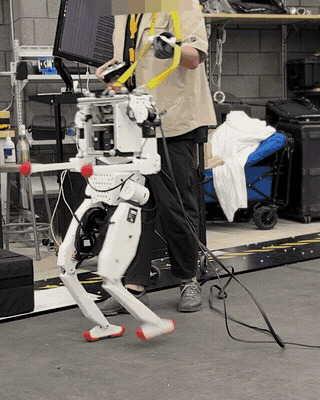
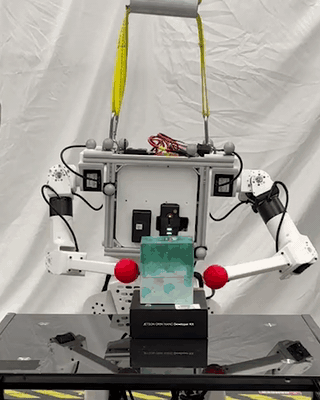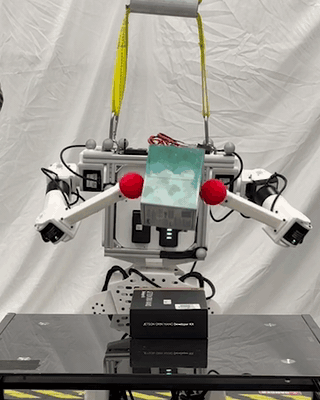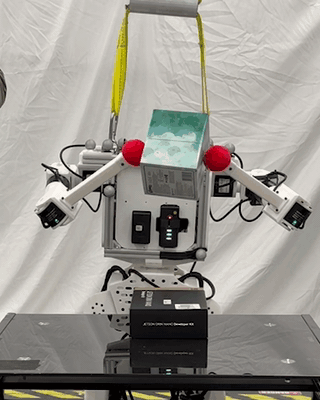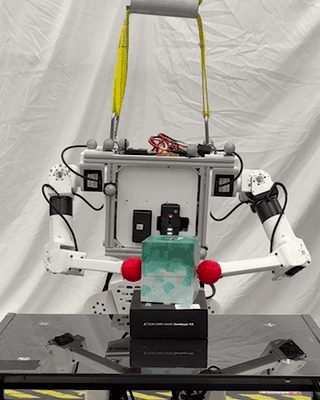
- Arcadian: Open-Source Humanoid Ecosystem for Accessible and Customizable Research and EducationUnder review at IEEE International Conference on Robotics and Automation (ICRA), 2027 ICRAOngoing: V2 with new features is in progress.